Bi-Weekly Progress Gantt Chart
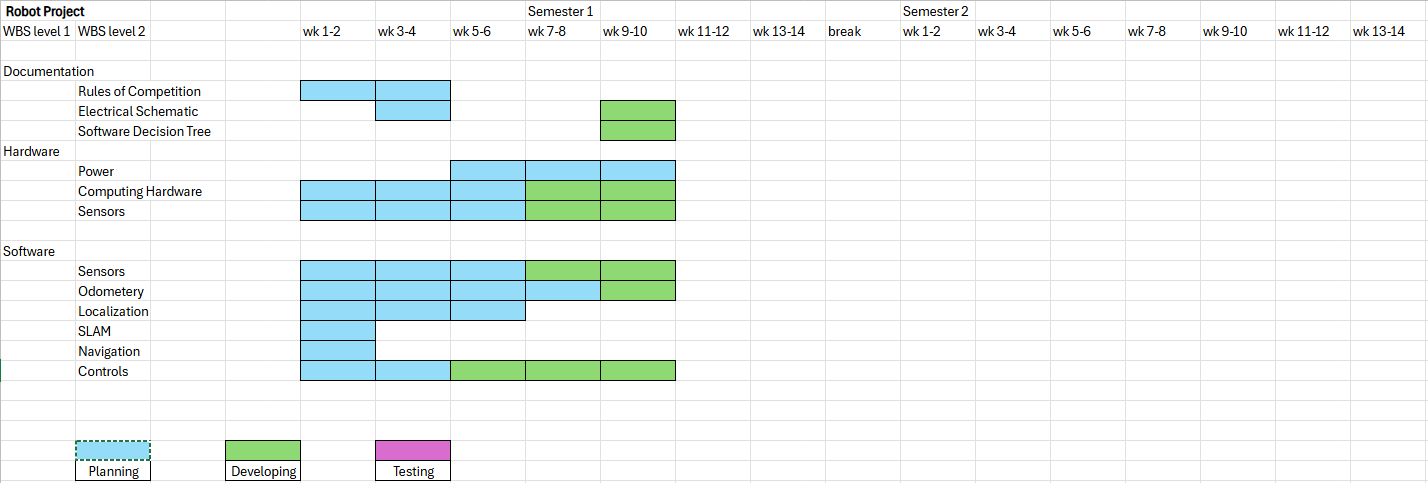
This chart was incorporated by taking a screenshot and adding it here as an image.
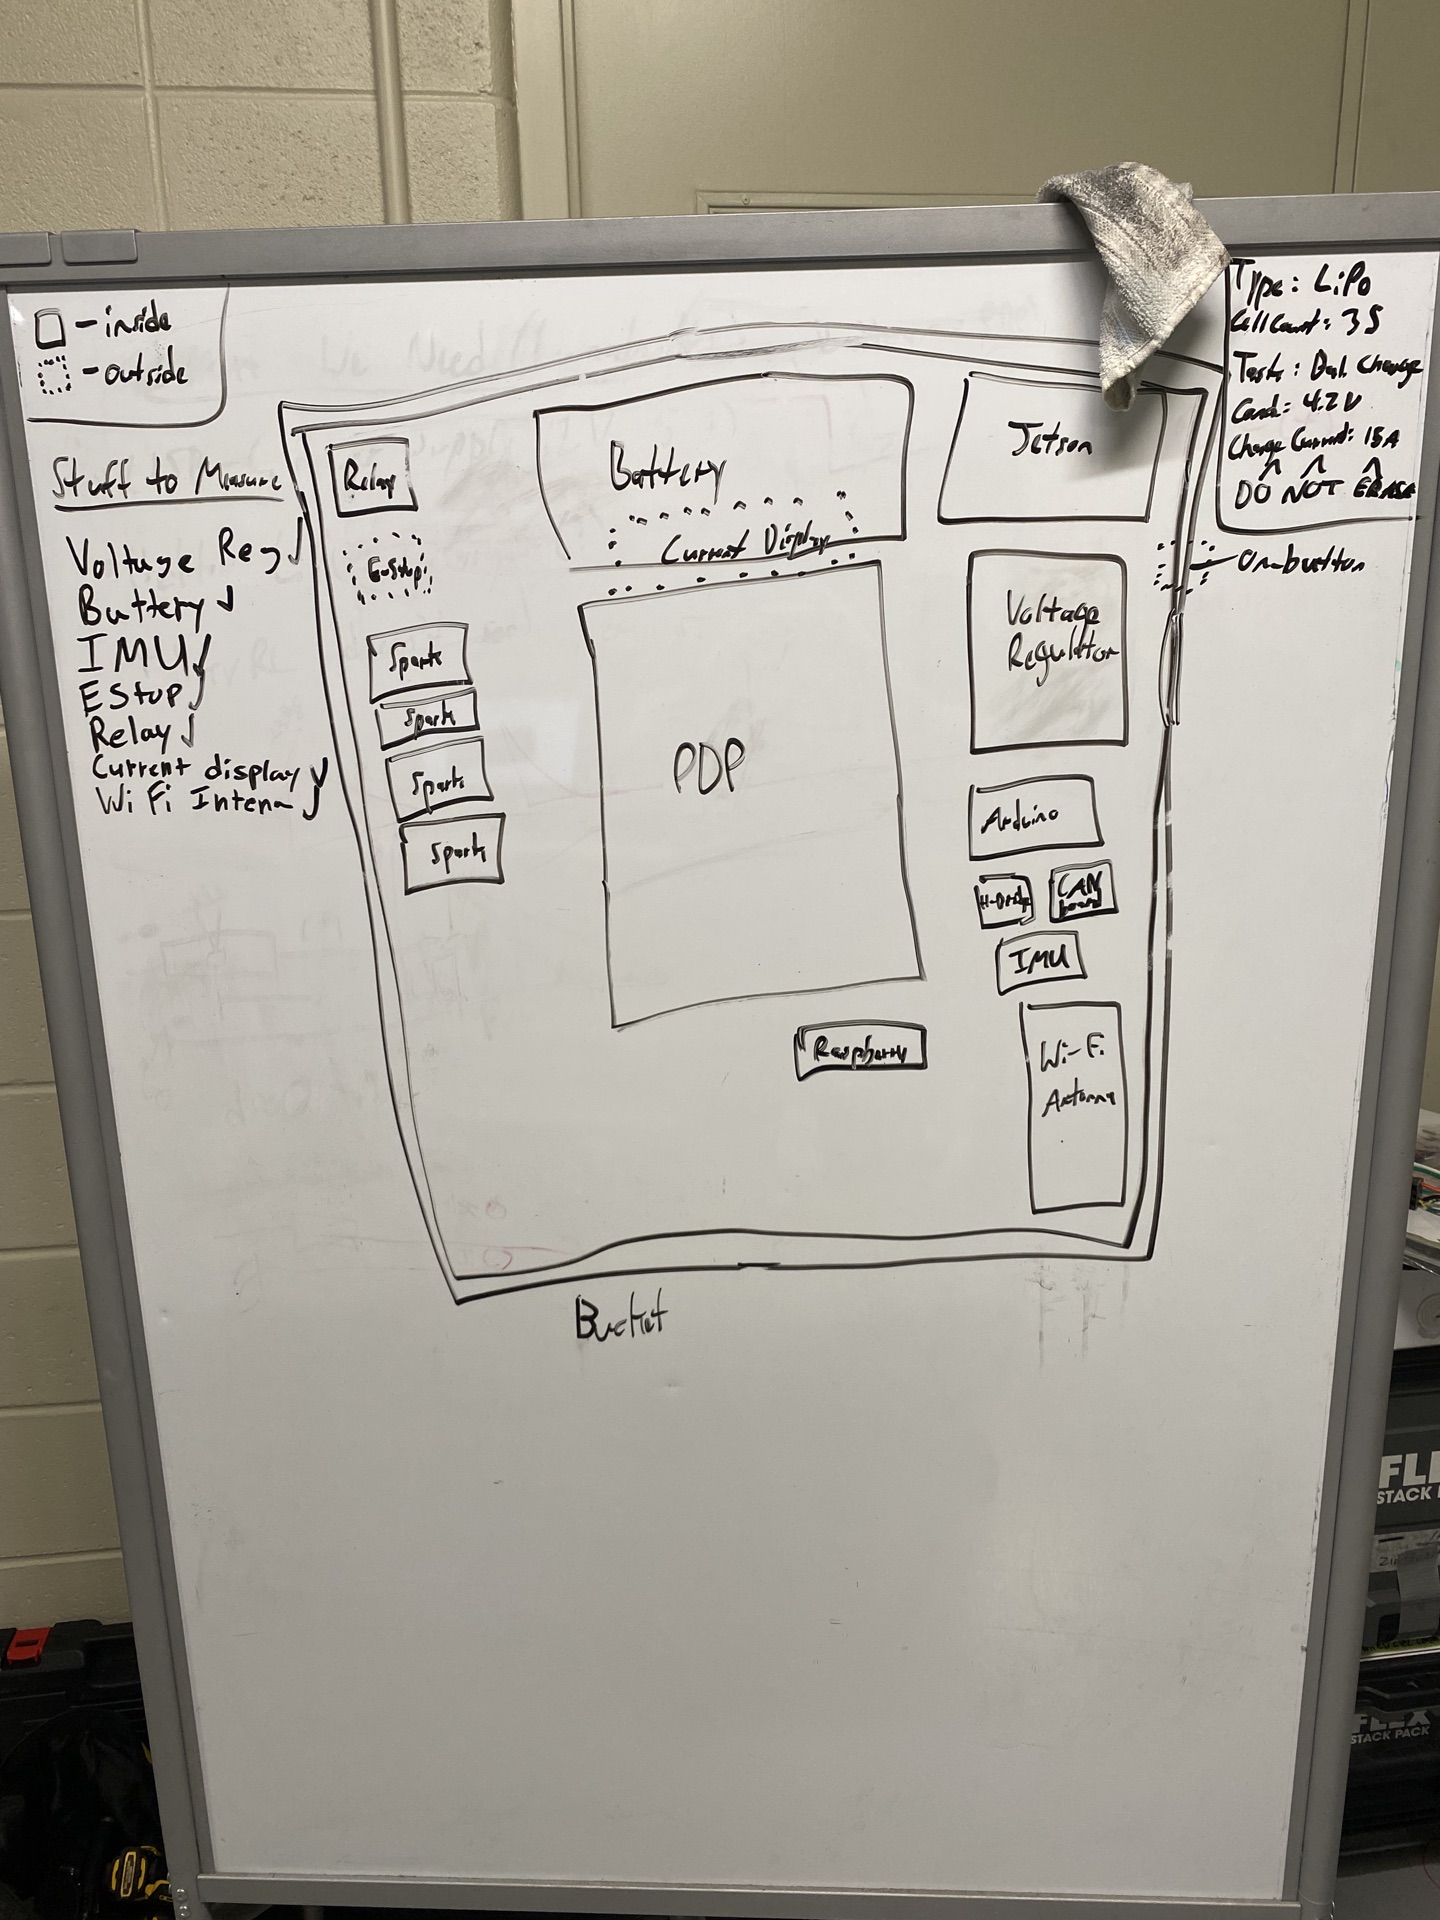
This week, our team worked on creating a layout for the new rover electrical box. We also took measurements of the current and new planned components to create CAD models. These CAD models were especially important for completing documentation for the required NASA PDR report. The PDR report is used to select the teams that advance to the KSC competition in May.
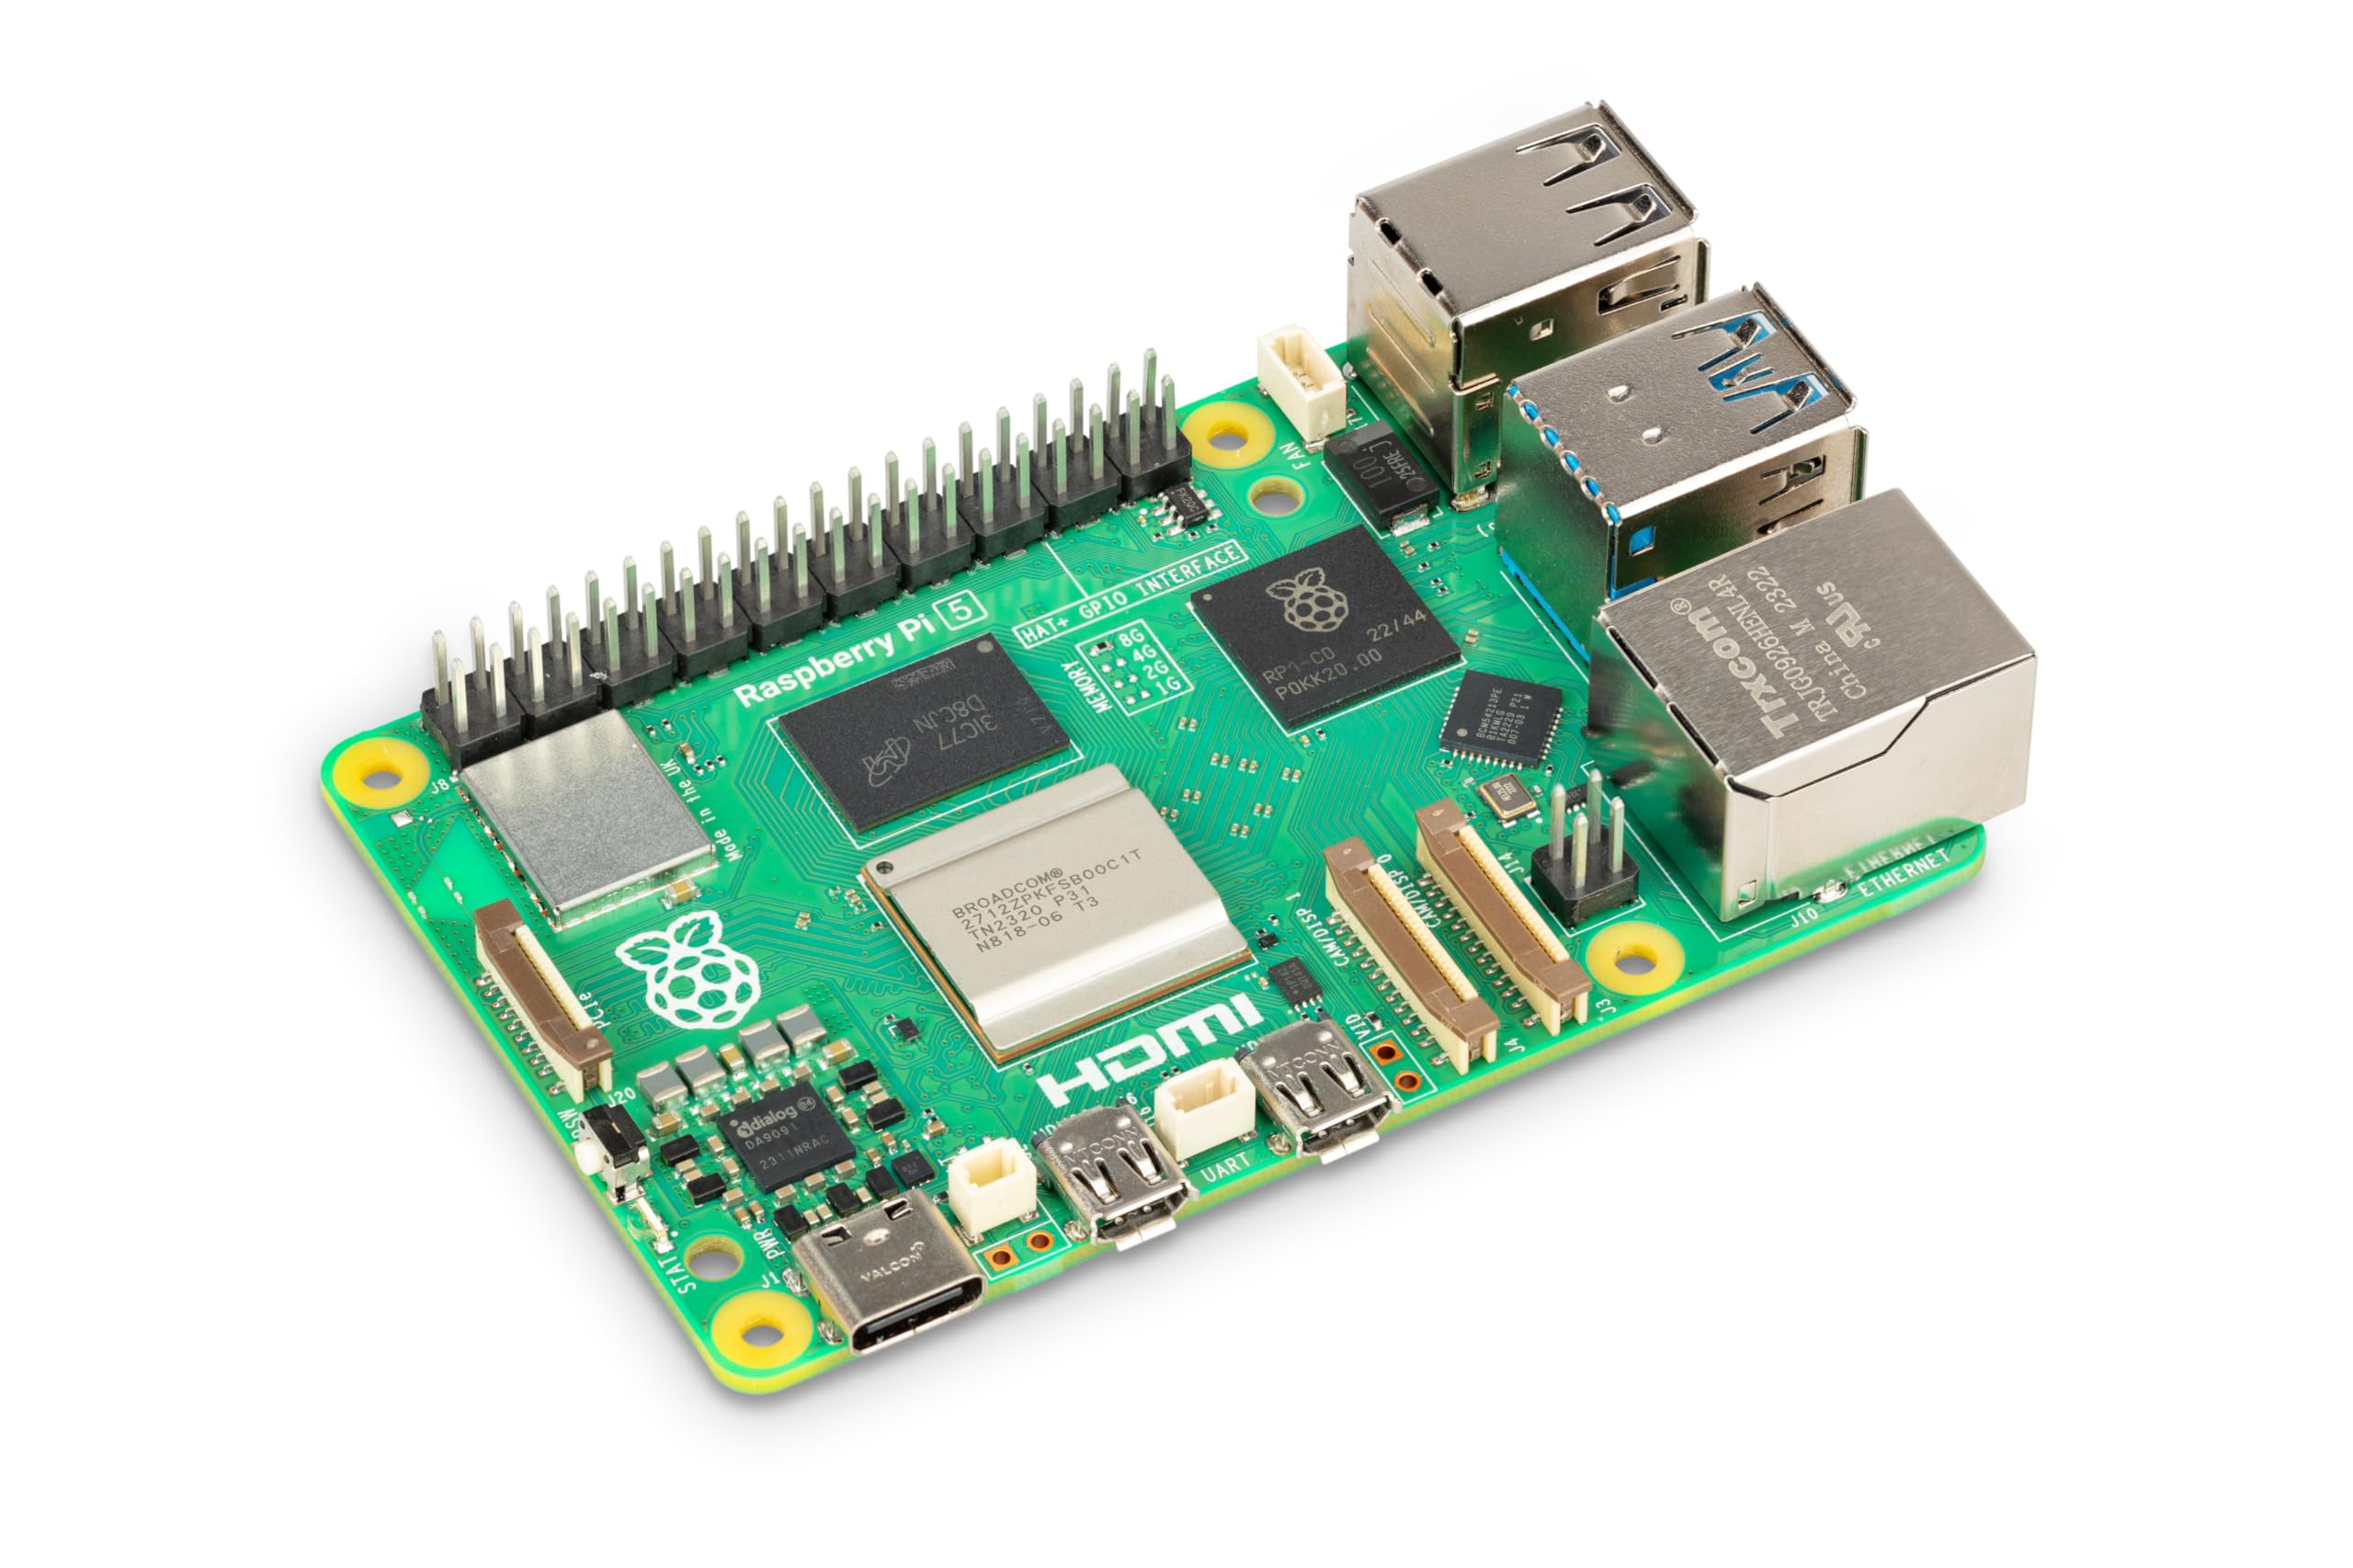
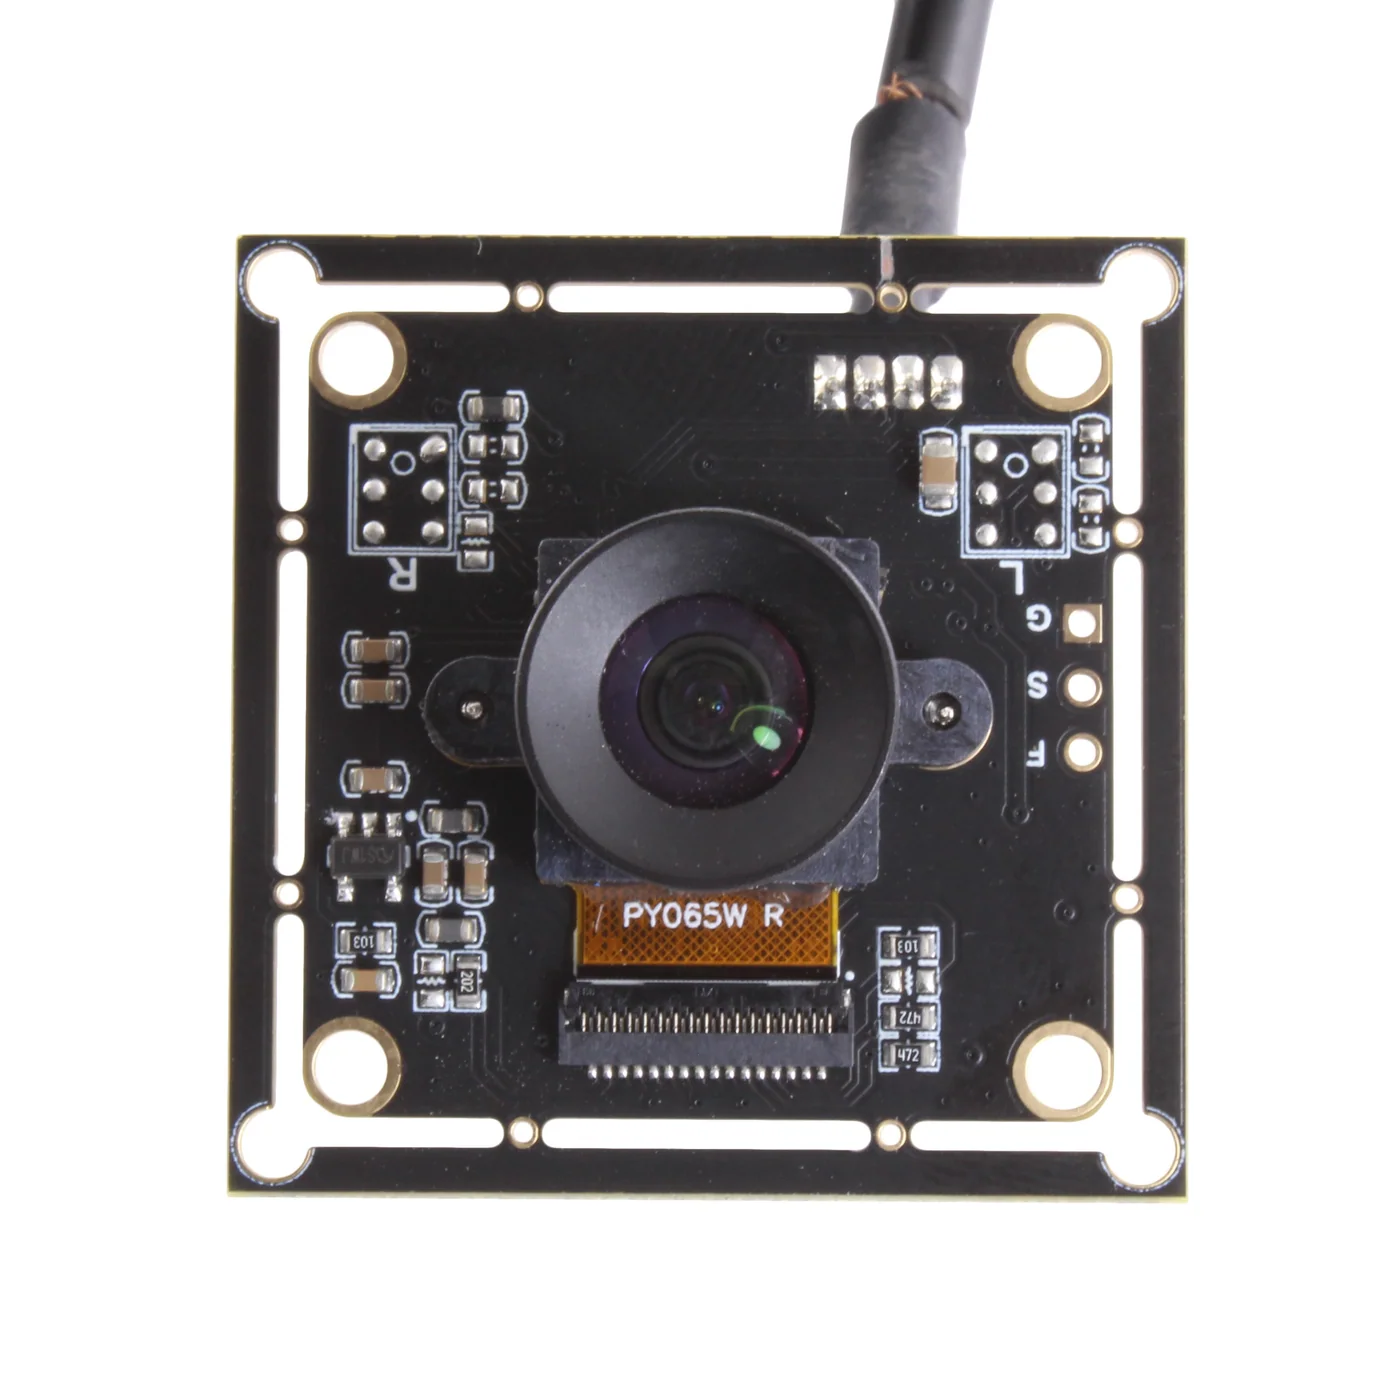
This week, our team met with Dr. Rose and the Engineering Safety Department to discuss the use of the Lunabotics shed for robot testing and development. We will need to perform a lot preparation before we can use it, including cleaning it, fixing the ventilator, completing a medical evaluation, and getting fitted for respirators. We also performed further testing into multi-camera AprilTag processing and decided to test using a Raspberry Pi 5 with simpler USB cameras to offload processing from the Jetson.
This week we were able to successfully acheive full driver control and test it on the robot. We also performed more testing with AprilTag tracking from the Jetson hardware.
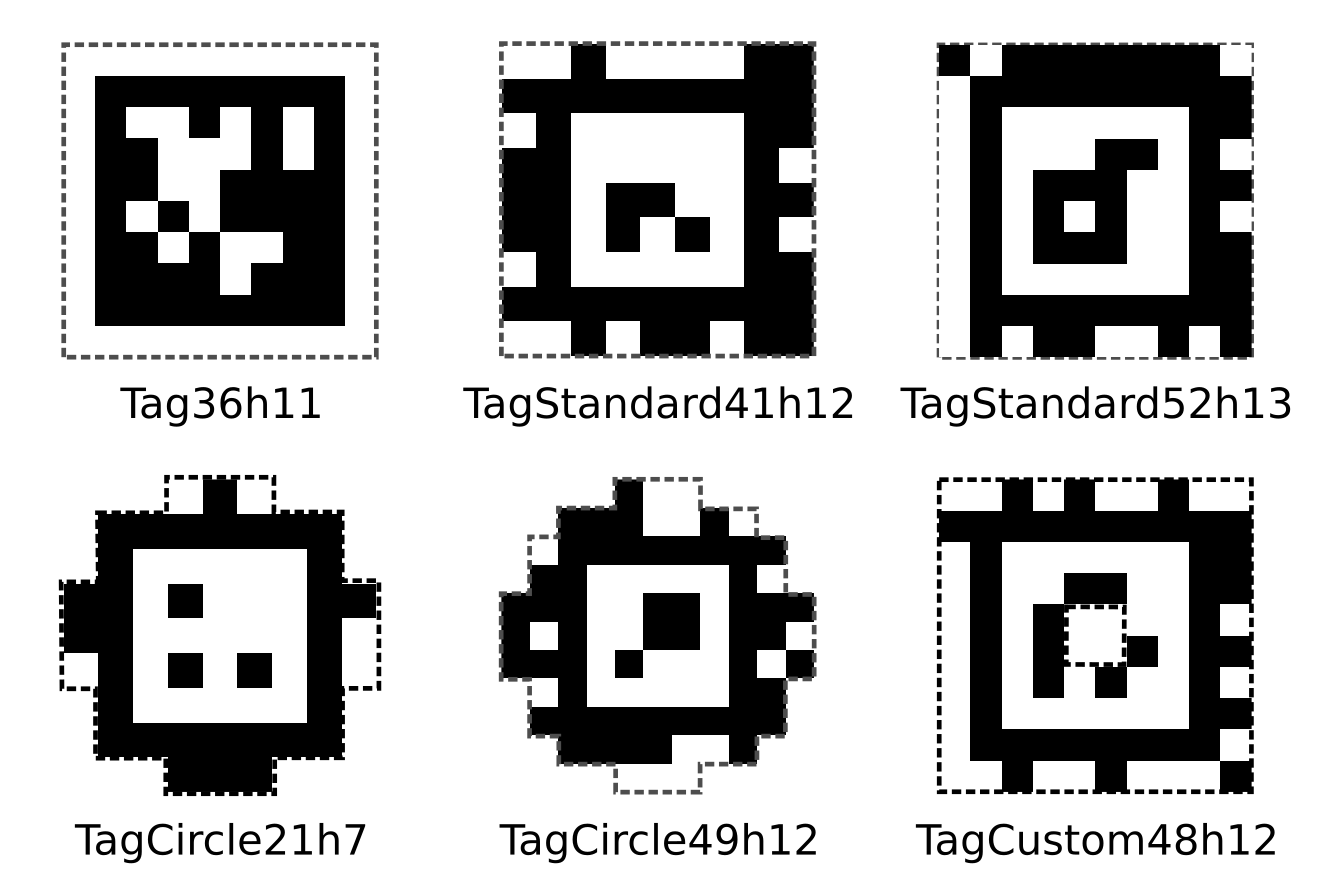
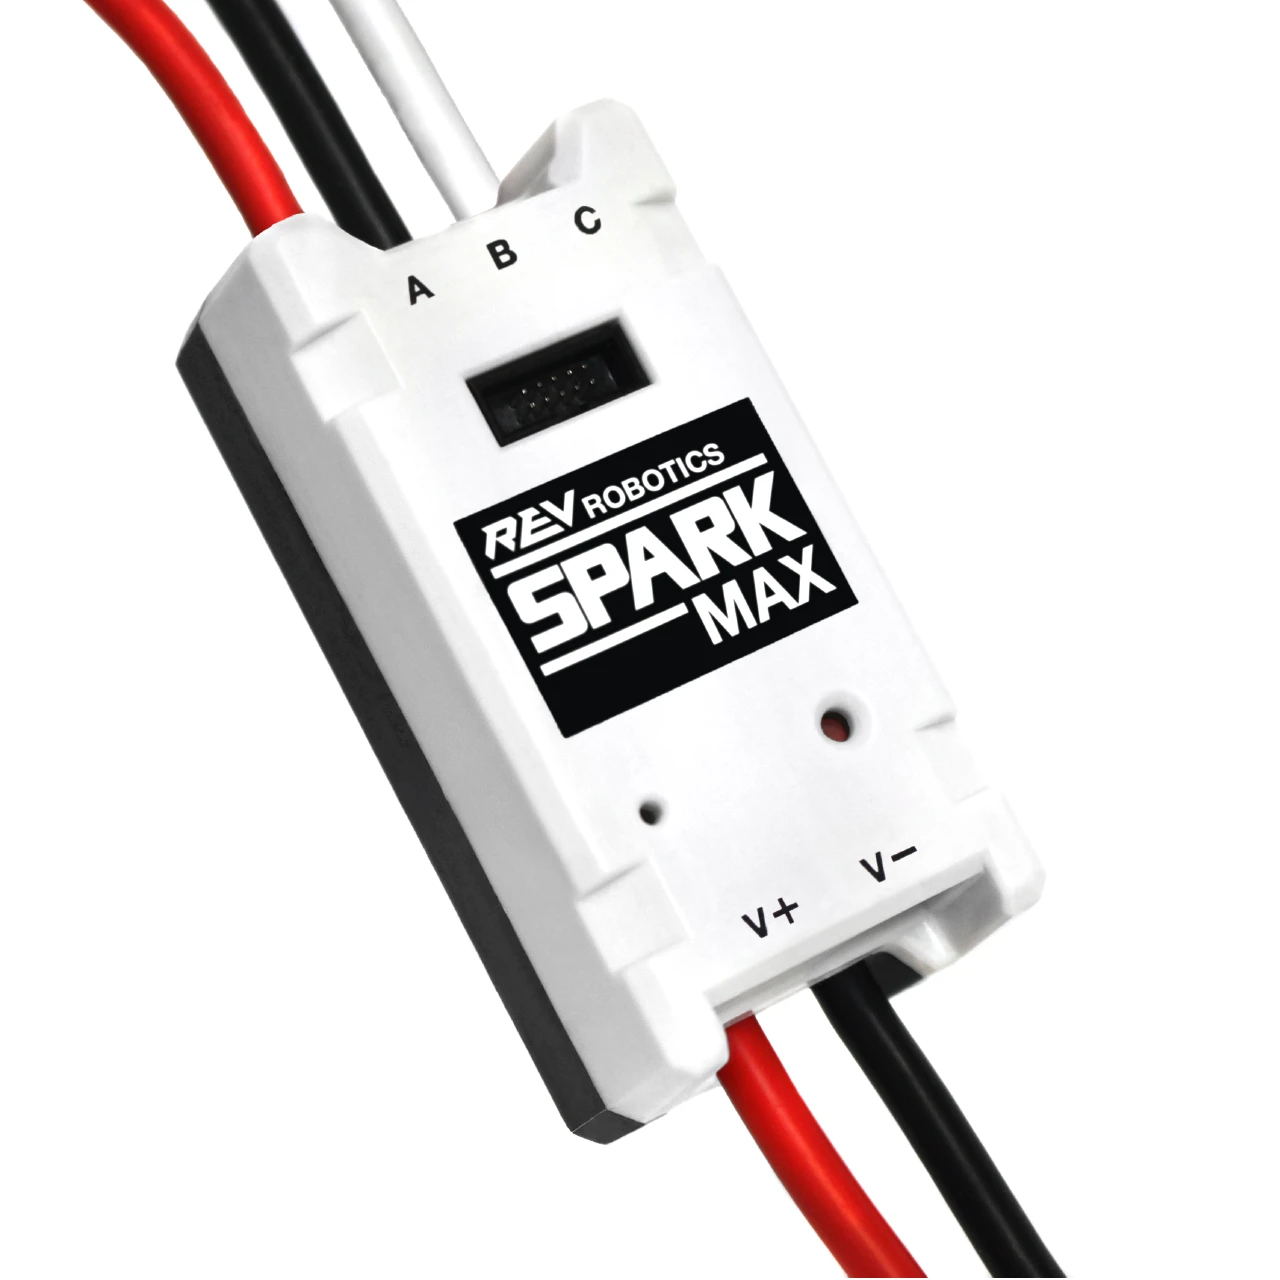
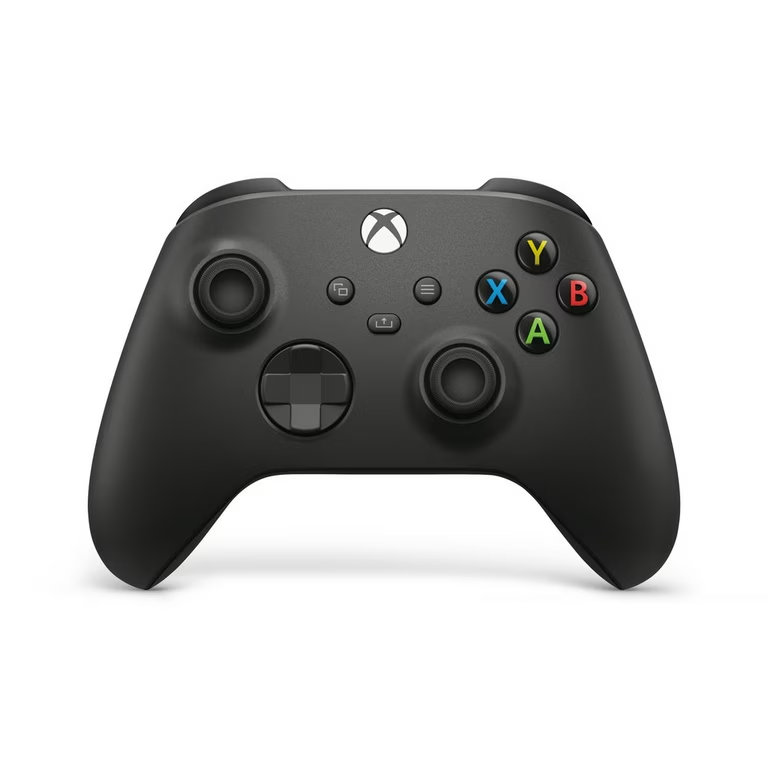
This week, our team reviewed the feedback from the Auburn PDR presentation and the requirements for the upcoming NASA PDR. We also successfully developed and tested code for controlling the robot's SparkMAX motor controllers using an Xbox controller over Bluetooth. We also developed code for locating AprilTags using an OAK-D camera.
There was no progress update this week because of fall break and the PDR presentation.
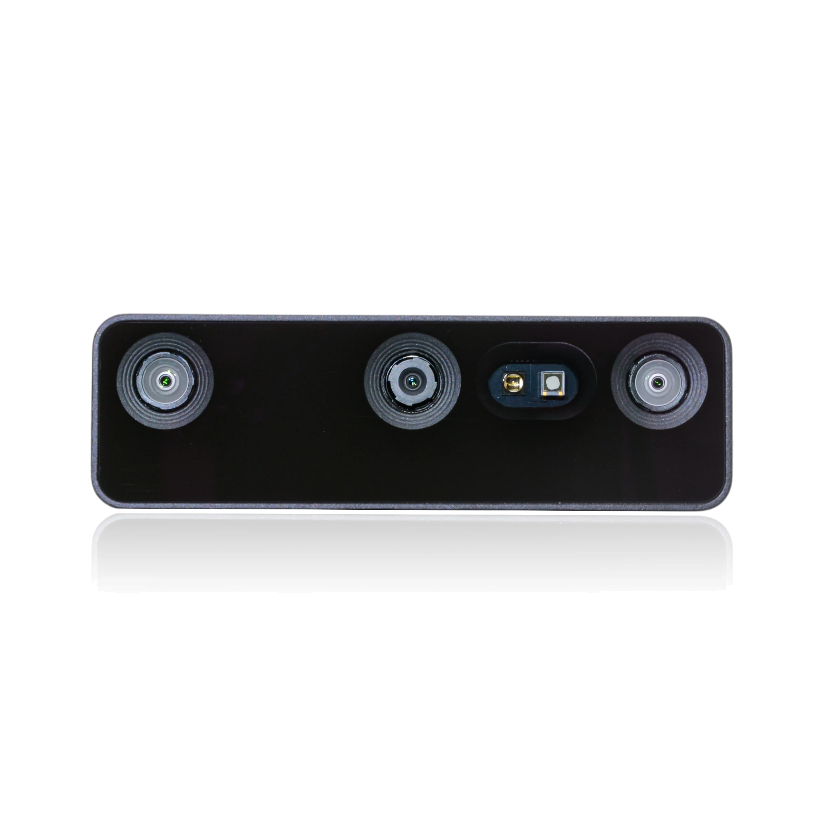
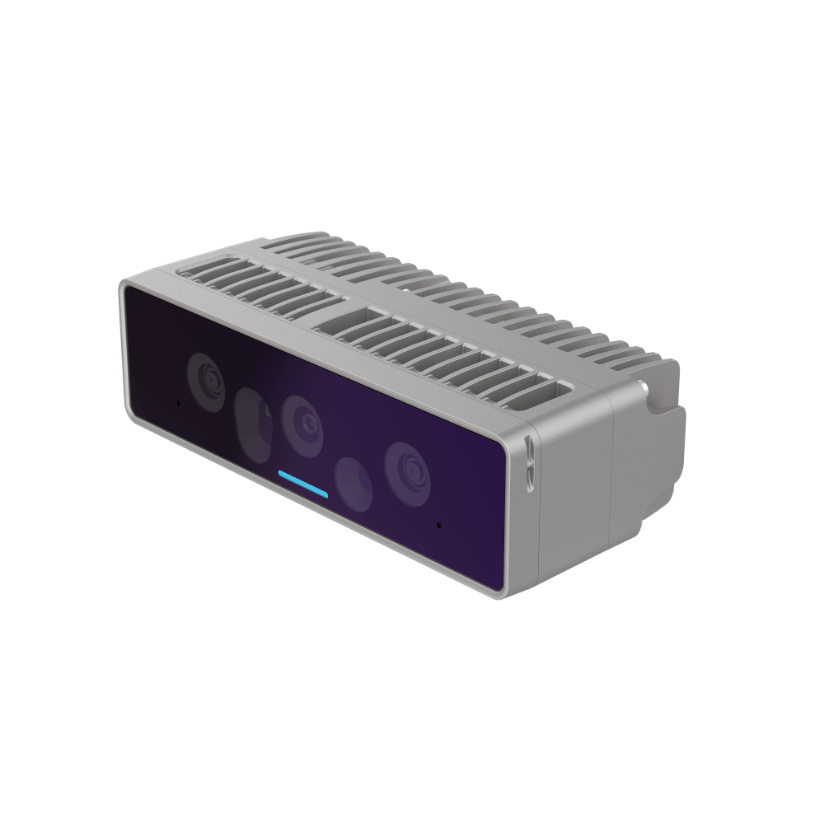
This week we completed our first initial deliverables for NASA: the Statement of Rights, Statement of Support - Faculty, Statement of Support - Institution, and Project Management Plan (PMP). We also researched and found several options for localization devices.
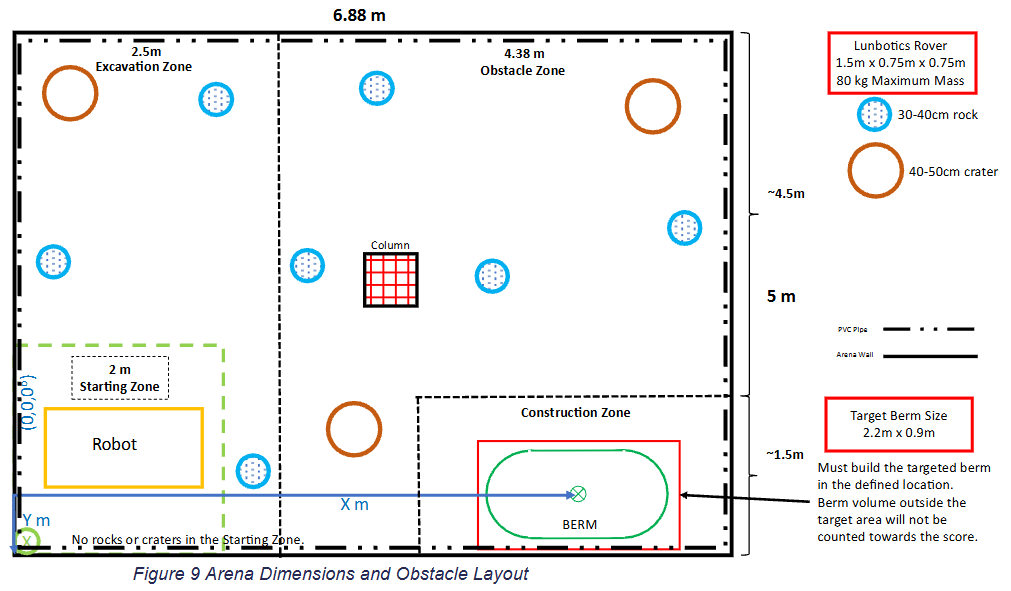
This week we reviewed the newly released NASA Challenge Guidebook. We continued to brainstorm ideas and plans for autonomy, which is emphasized as a significant part of the competition this year. We also started work on project documentation and deliverables that are due soon.
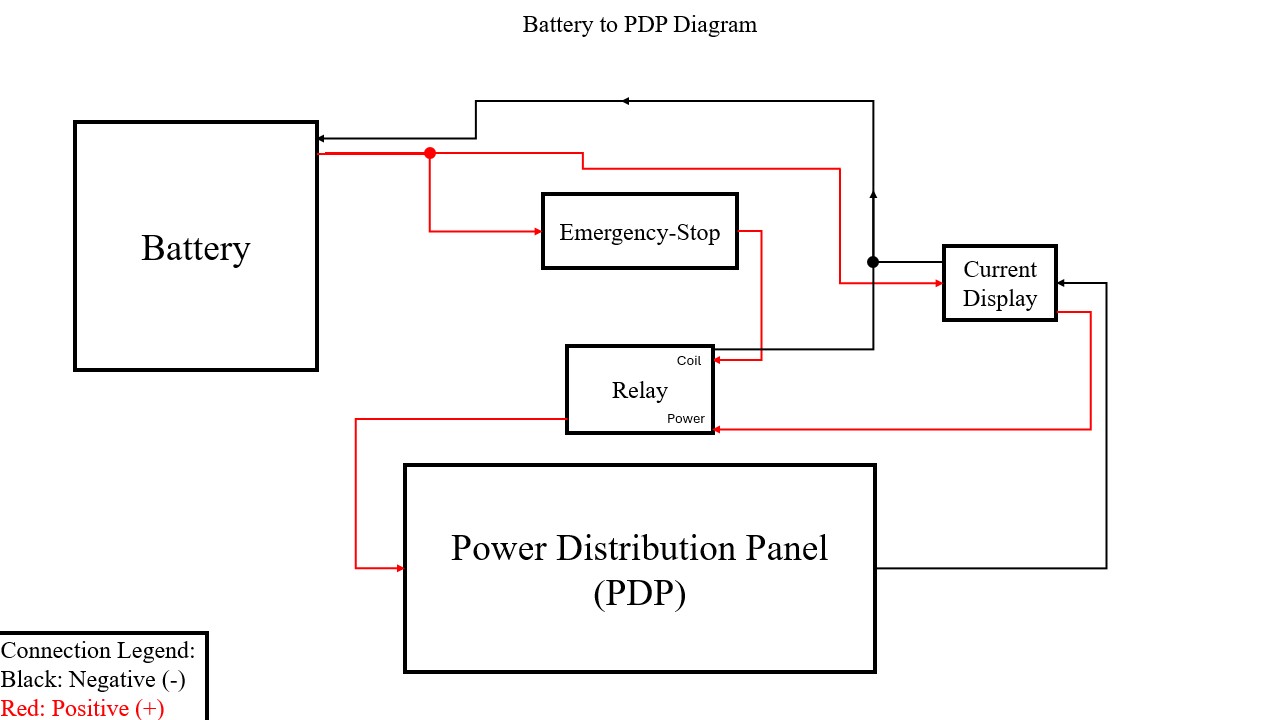
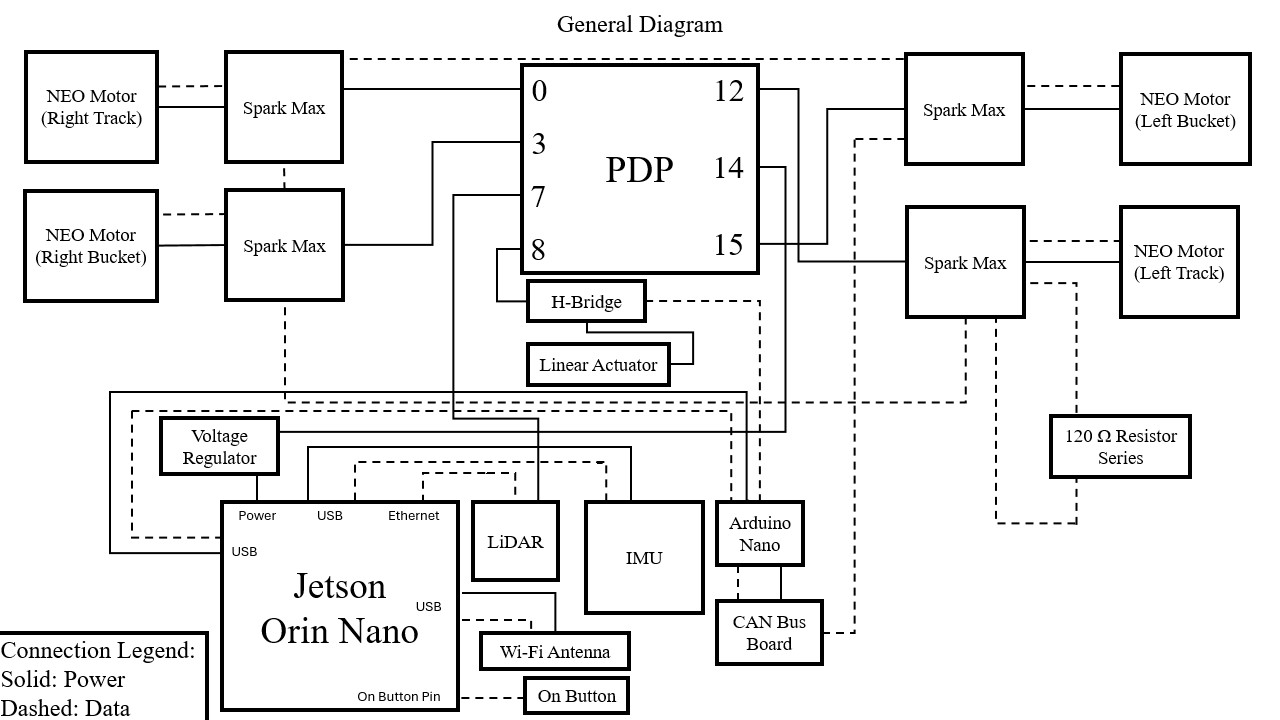
This week we performed more research into sensors and localization solutions. We also evaluated the current code and electronics on the old robot. At the end of the week, NASA officially released the new guidebook for 2026-2027!
This week we met with Dr. Rose and divided our group members into subteams. While NASA has yet to release the official rules for this year, we began brainstorming ideas and reviewing the documentation/outreach requirements.
This week we officially established the Auburn University Lunabotics team for 2026-2027! Our SMEs are Dr. Chad Rose and Josh Medler. The team is comprised of 3 ECE students and 10 MechE students. For this week, we met with Medler and reviewed the current state of the robot and lab.